Back to projects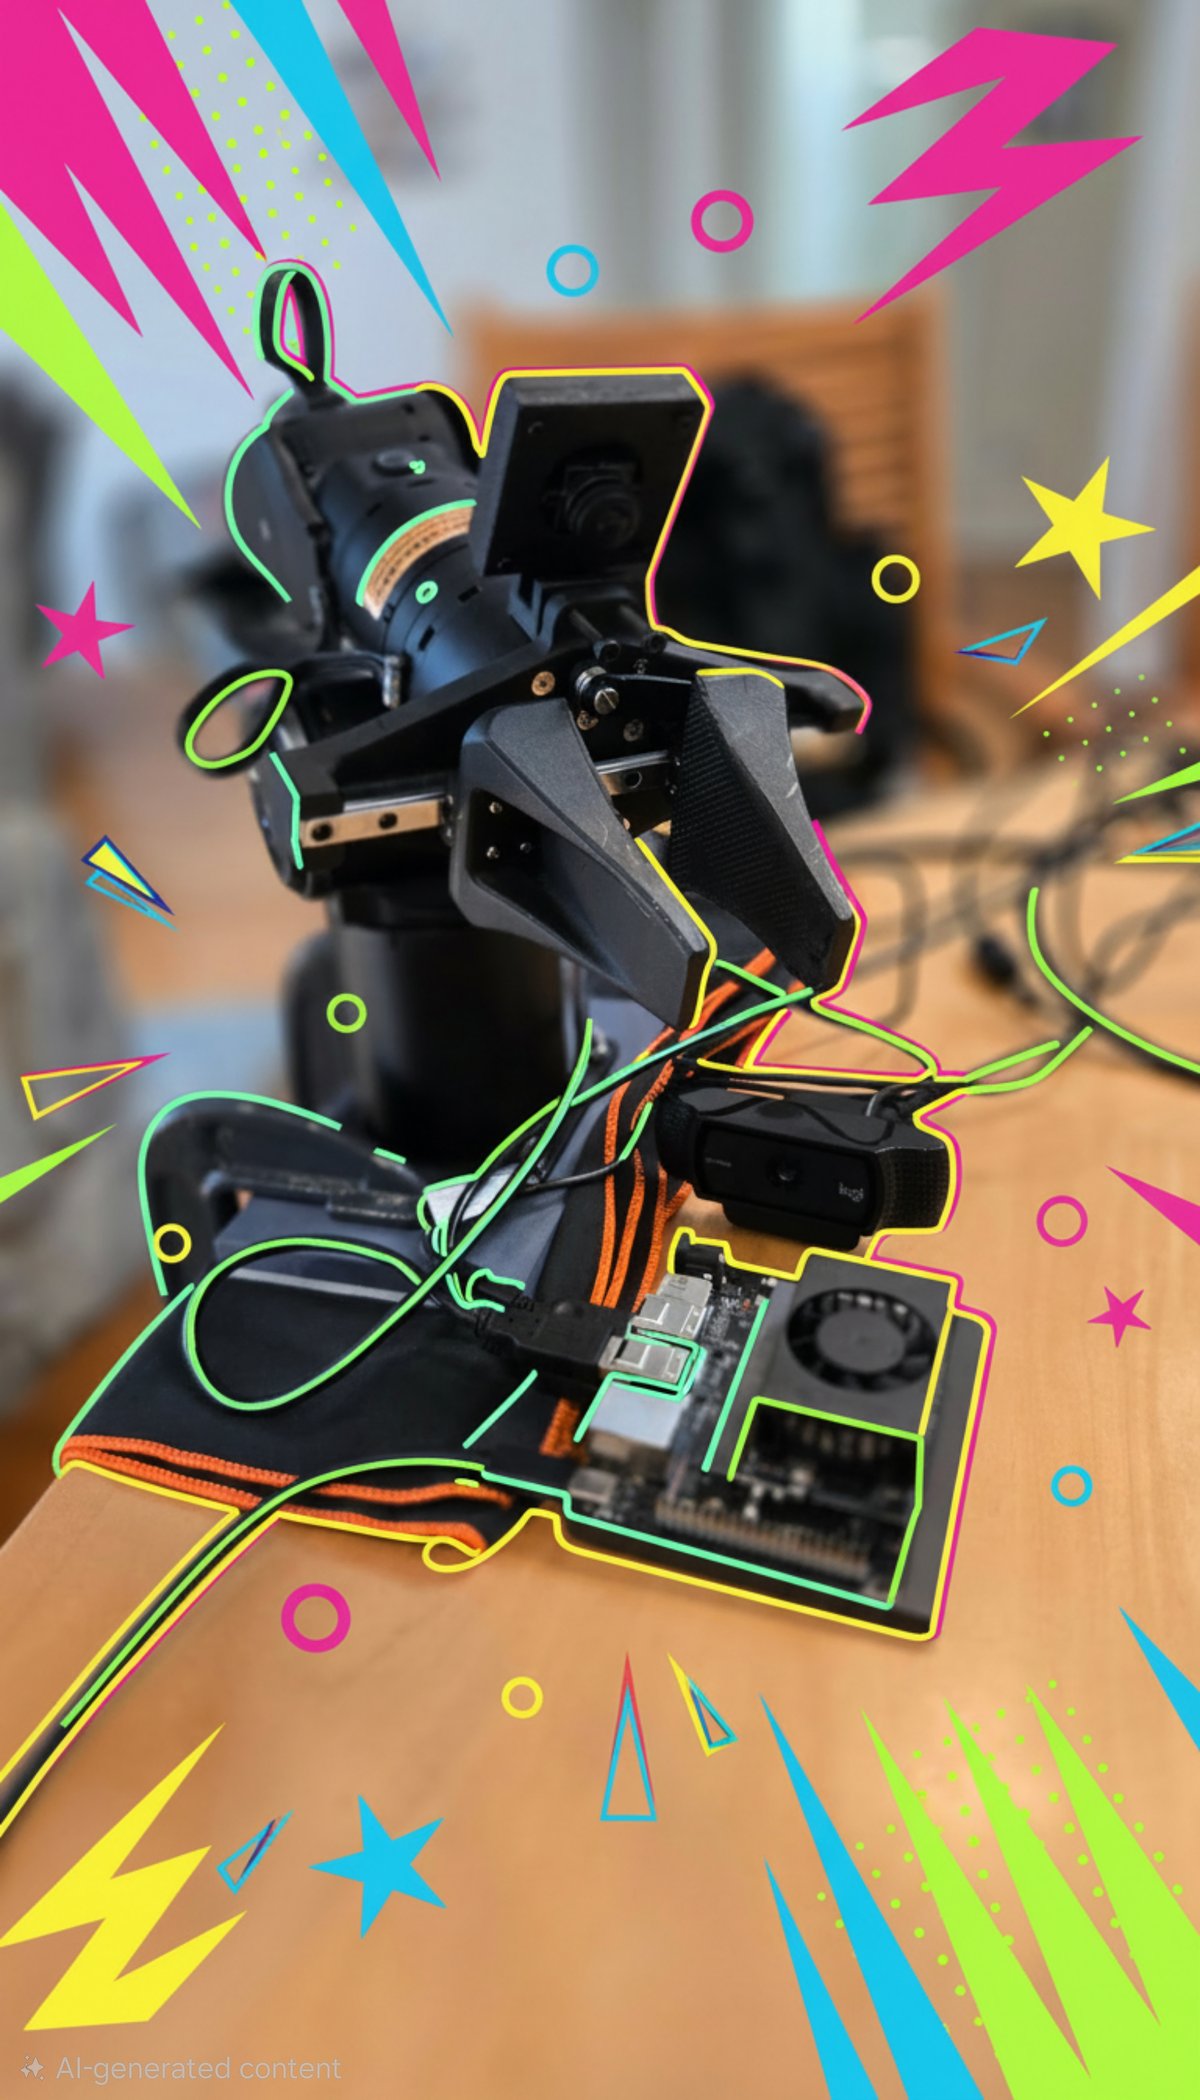
Tesseract PiPER
A living deployment runbook for the AgileX PiPER arm on an NVIDIA Jetson Orin Nano, run as a remotely operated, unattended robot: Tailscale remote access, CAN bus bring-up, WebRTC camera streaming, and systemd services that bring everything back by itself after a reboot.
RoboticsNVIDIA JetsonEmbodied AIDocumentation